Year
2021
Summary

This research develops programmable active materials that function like soft robots without electronics or external control systems. Using 3D-printed liquid crystal elastomers, the work engineers materials that sense temperature and autonomously deform, fold, and locomote, demonstrating how microscopic material structure can be programmed to produce complex robotic behavior.

Year
2026
Summary

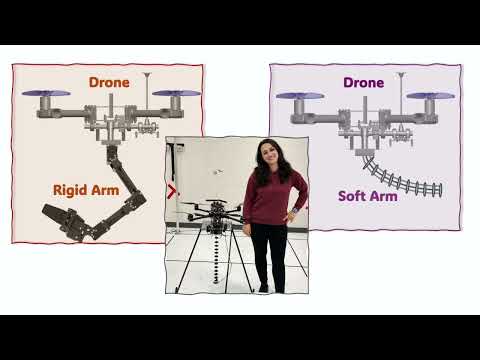
This research develops drones with soft robotic arms capable of safely grasping and transporting objects in challenging environments. By combining predictive modelling with visual feedback, it overcomes control challenges associated with soft materials. The work advances intelligent, adaptive aerial robotics for applications such as emergency delivery and hazardous environments.

Year
2026
Summary

This research develops soft robots using liquid crystal elastomers that act as artificial muscles. By designing materials at the molecular level and 3D printing them into responsive structures, researchers can create flexible robots that move like animals. These soft robots could navigate tight spaces during search-and-rescue missions after disasters.

Organisation
Year
2025
Summary

This thesis introduces Armando, a low-cost soft robotic gripper with proprioceptive sensing using a single flexible capacitive sensor and neural-network decoding. Achieving 99% accuracy, Armando enables precise finger-position estimation for applications in prosthetics, assistive care, and disaster response, advancing accessible tactile robotics inspired by human touch.